Andrés A. Peters
Associate Professor, Faculty of Engineering and Sciences
Universidad Adolfo Ibáñez, Santiago, Chile
I work on control theory for multi-agent systems, mainly vehicle platoons: how disturbances propagate along a string of vehicles, how unreliable communication changes that, and which performance limits no controller can beat.

Research
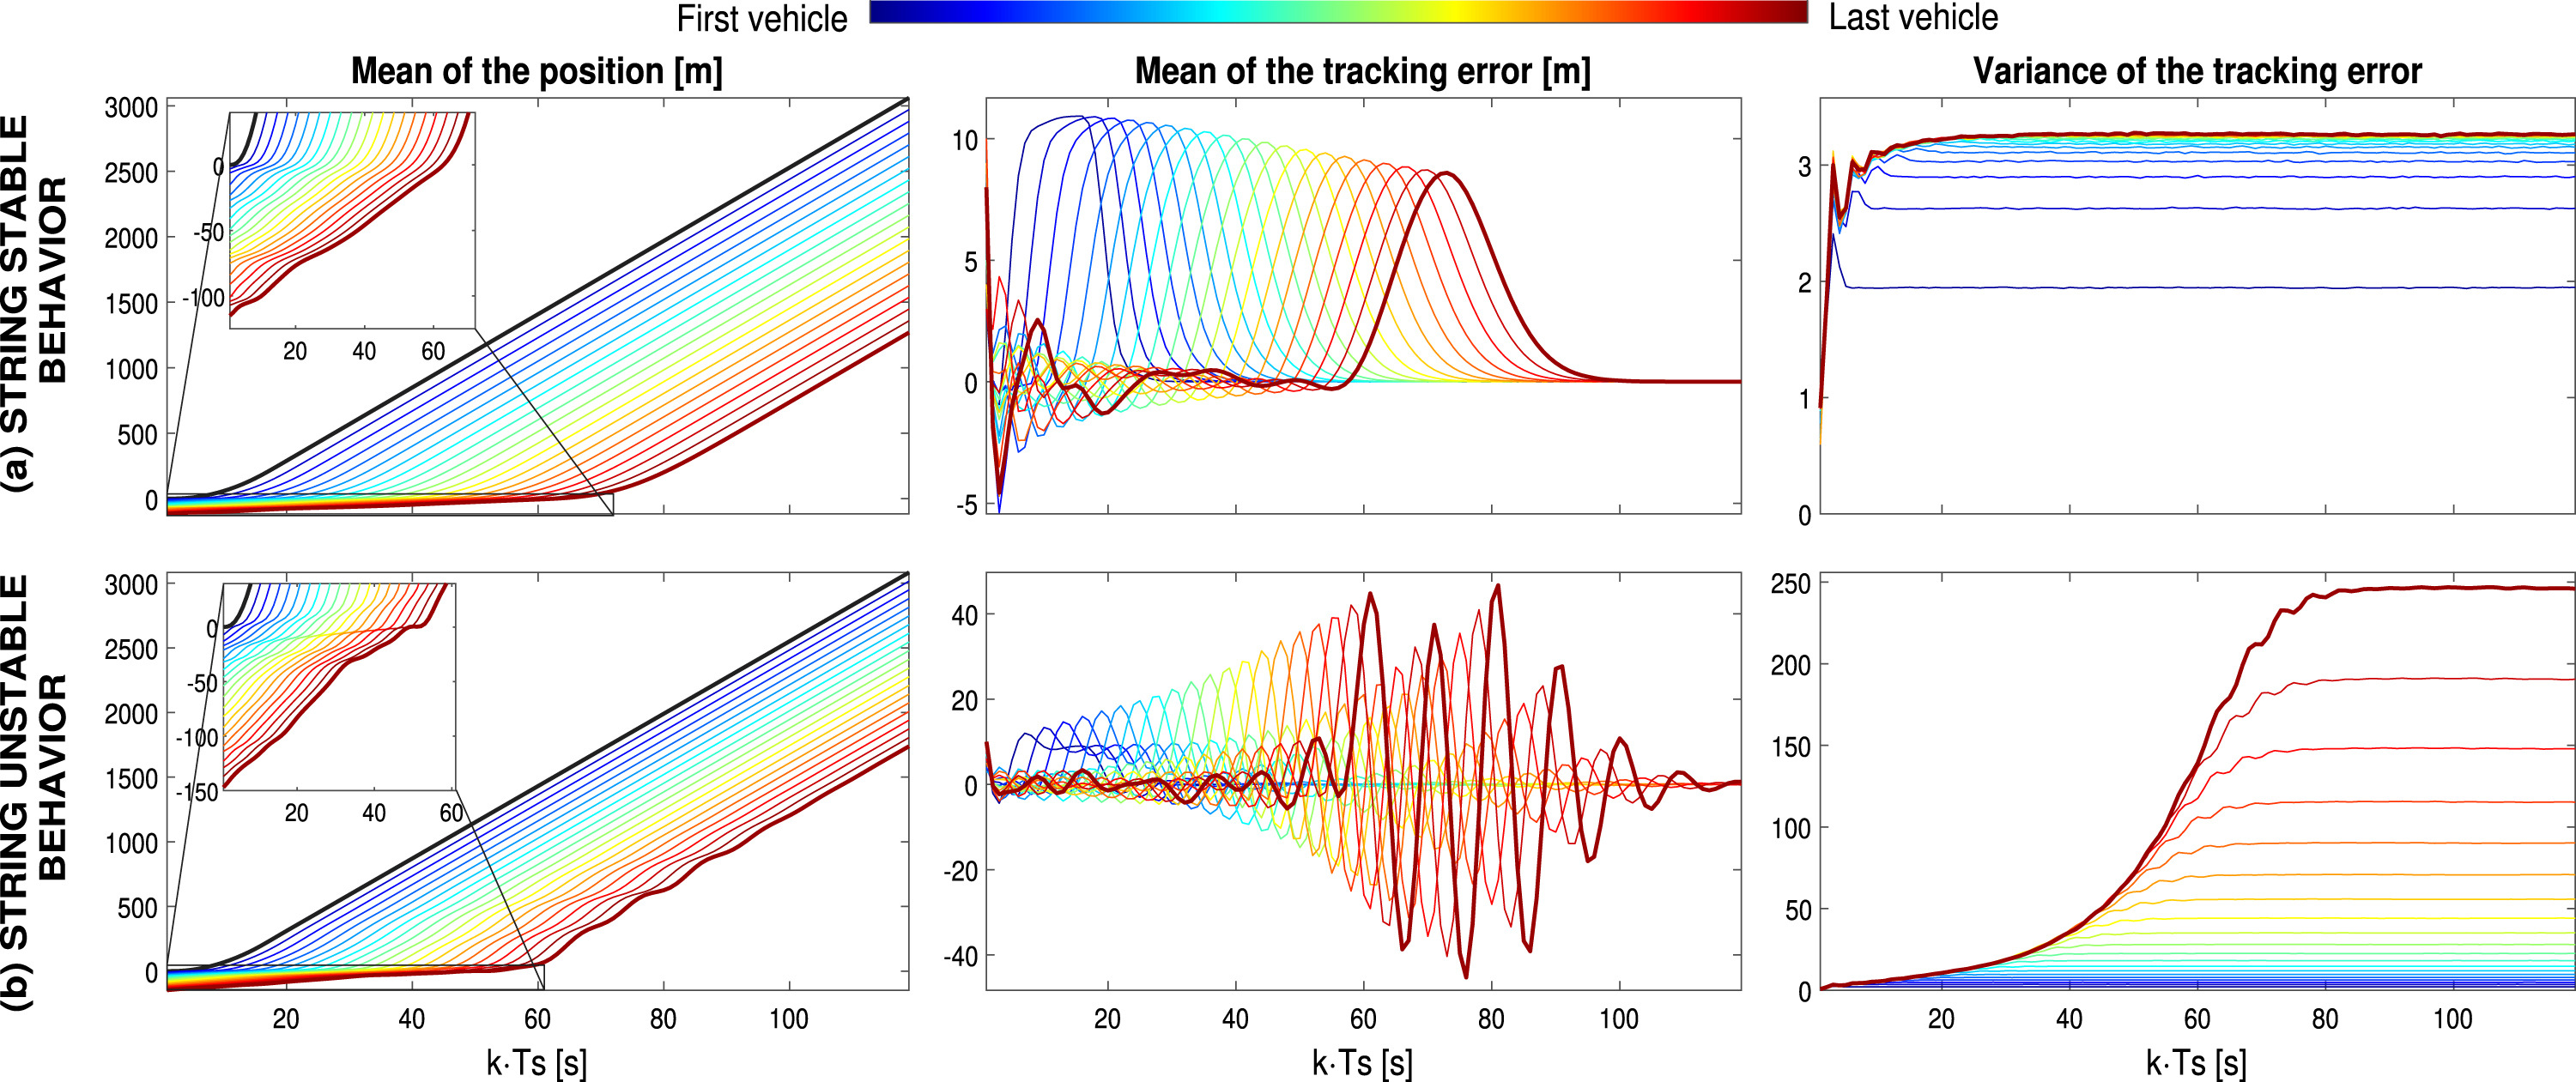
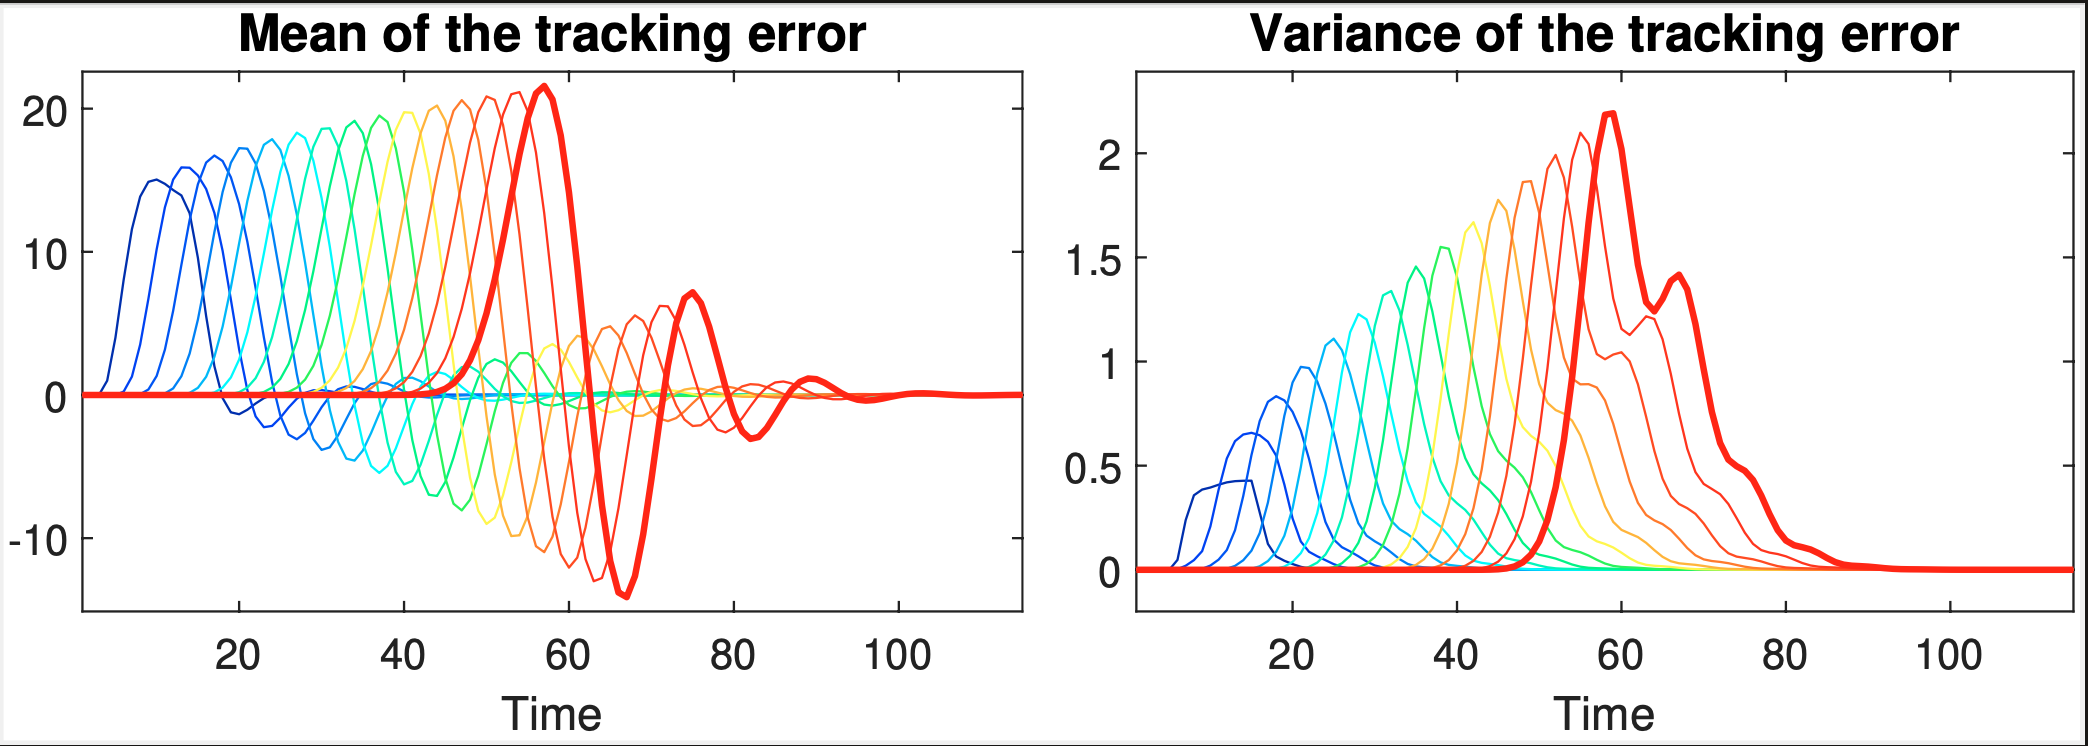
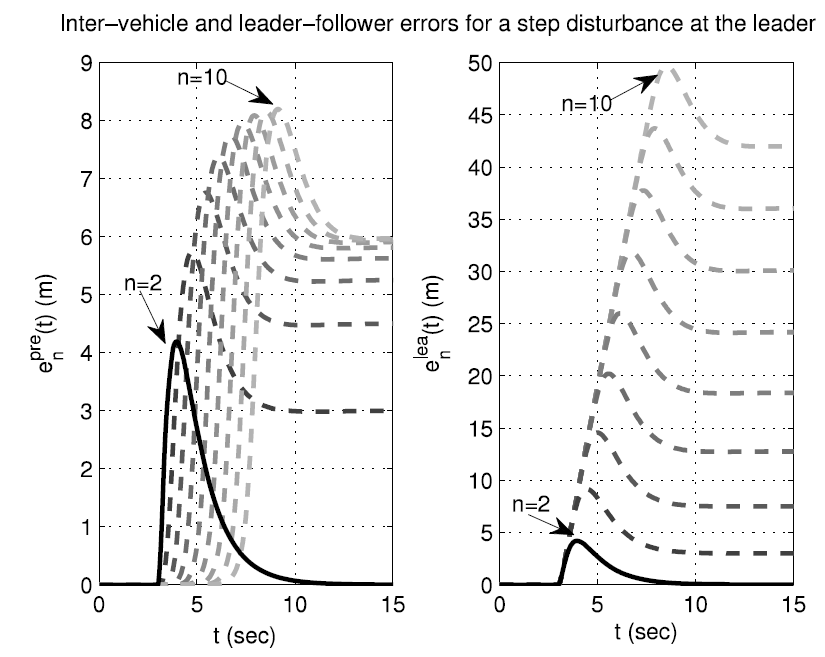
String stability of vehicle platoons
Conditions under which a disturbance at the head of a vehicle string is attenuated, not amplified, as it travels backwards, for different spacing policies and interconnection topologies.
- Leader tracking in homogeneous vehicle platoons with broadcast delays, Automatica 2014
- Cyclic interconnection for formation control of 1-D vehicle strings, European Journal of Control 2016
Platooning over unreliable communication
Stability and performance of cooperative platoons when vehicle-to-vehicle links lose packets, add noise, or deliver data with random delays, analysed in mean square and in expectation.
Performance limits in optimal control
Closed-form bounds on the best achievable H∞ performance under structural and parametric constraints, such as pole location or non-minimum phase zeros, and limits on the time headway that admits string stability.
Decentralized multi-agent models
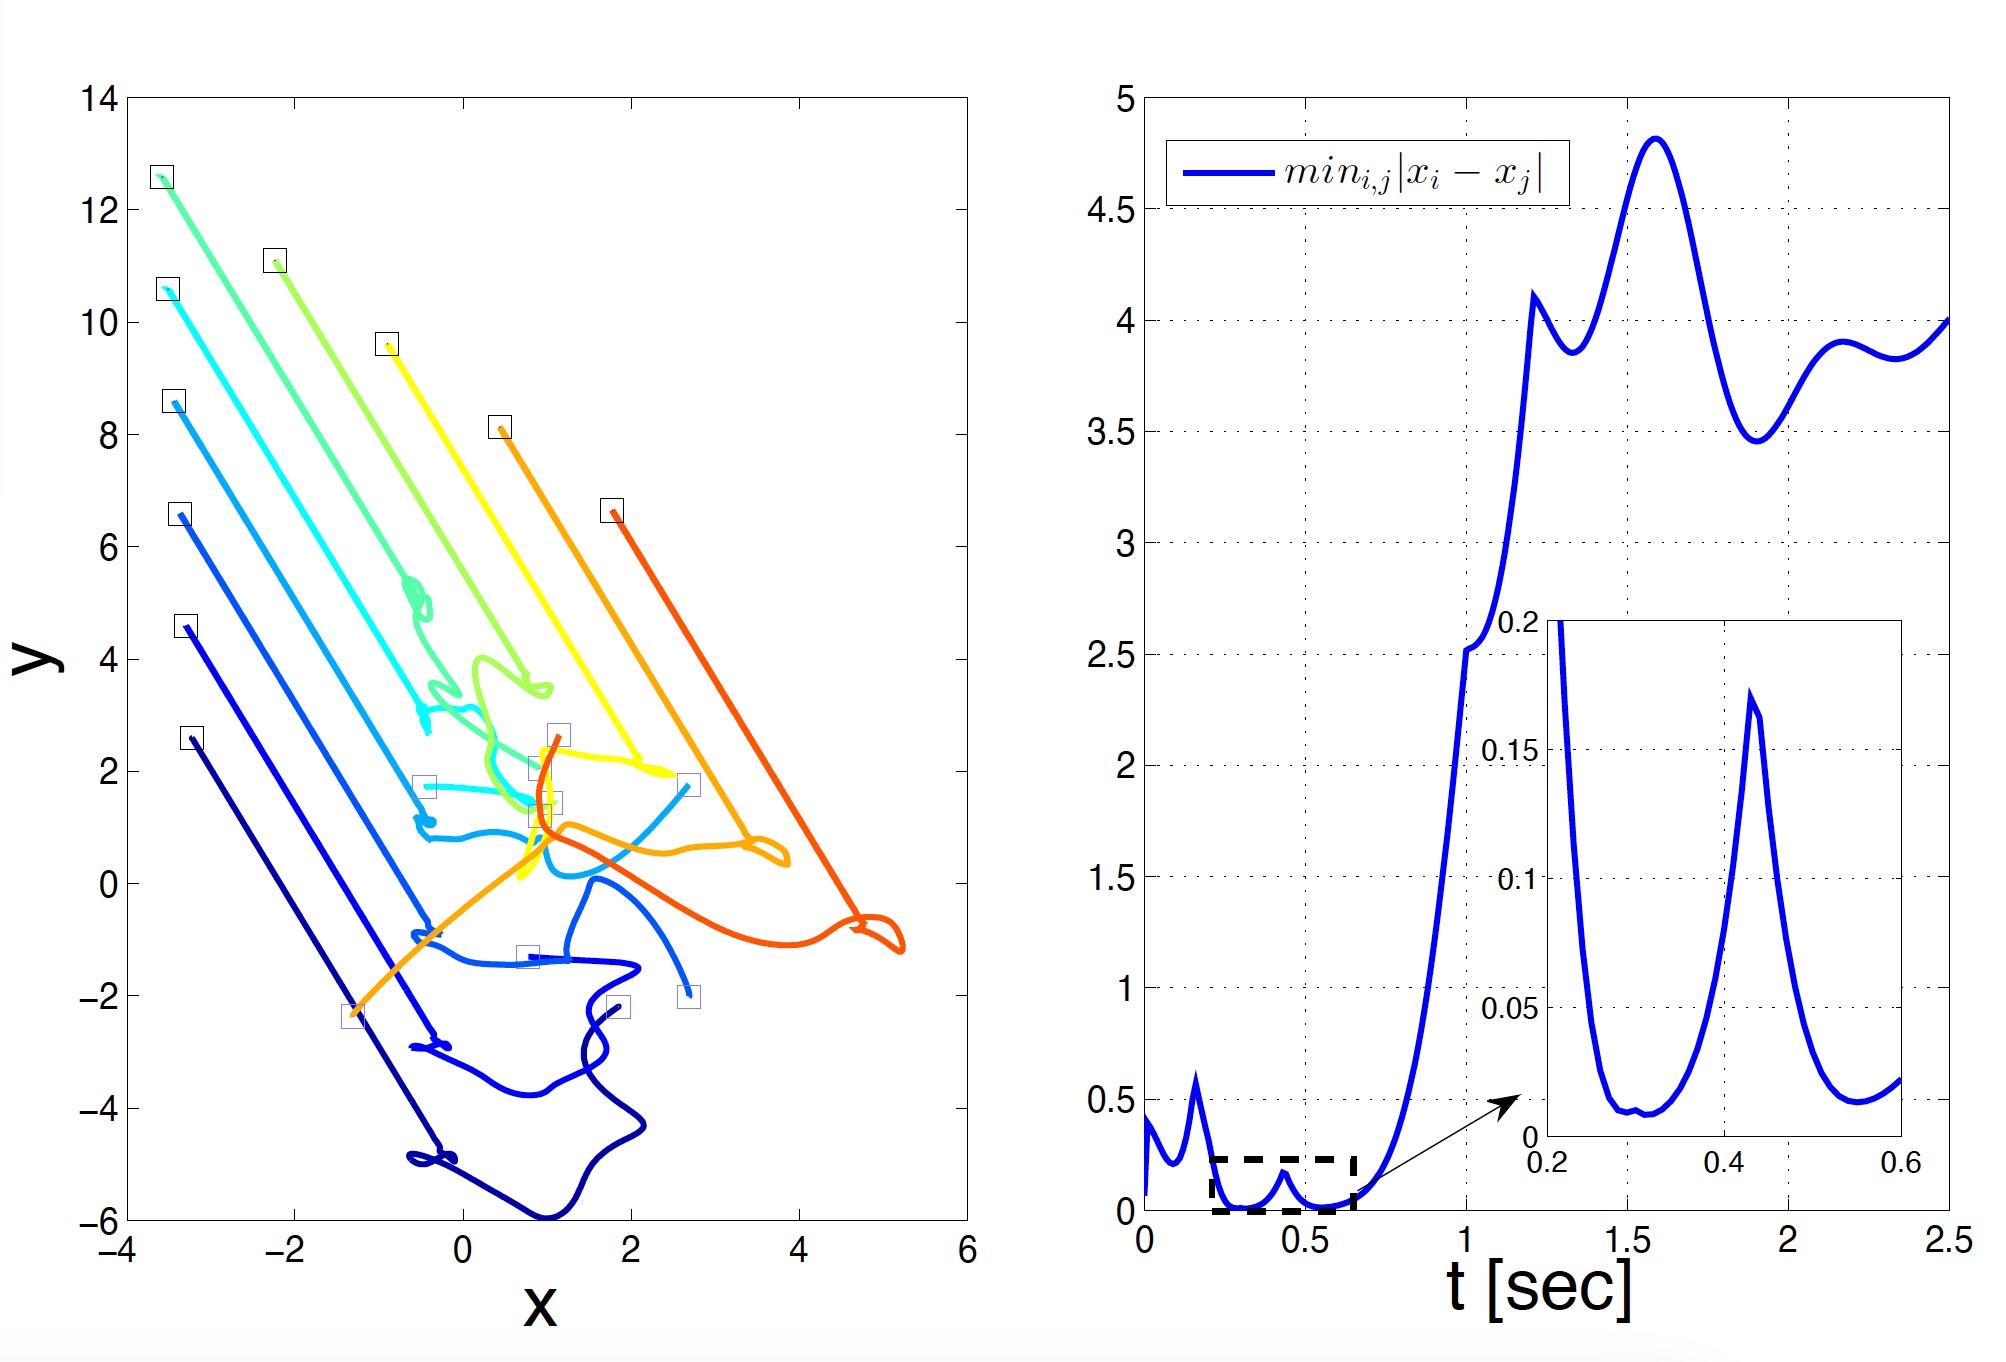
Simple local interaction rules, such as Cucker–Smale type flocking, that produce collision-free formations without a central coordinator.
- A collisionless singular Cucker–Smale model with decentralized formation control, SIAM J. Applied Dynamical Systems 2019
- Collisionless and decentralized formation control for strings, Networks and Heterogeneous Media 2025
Experimental platforms
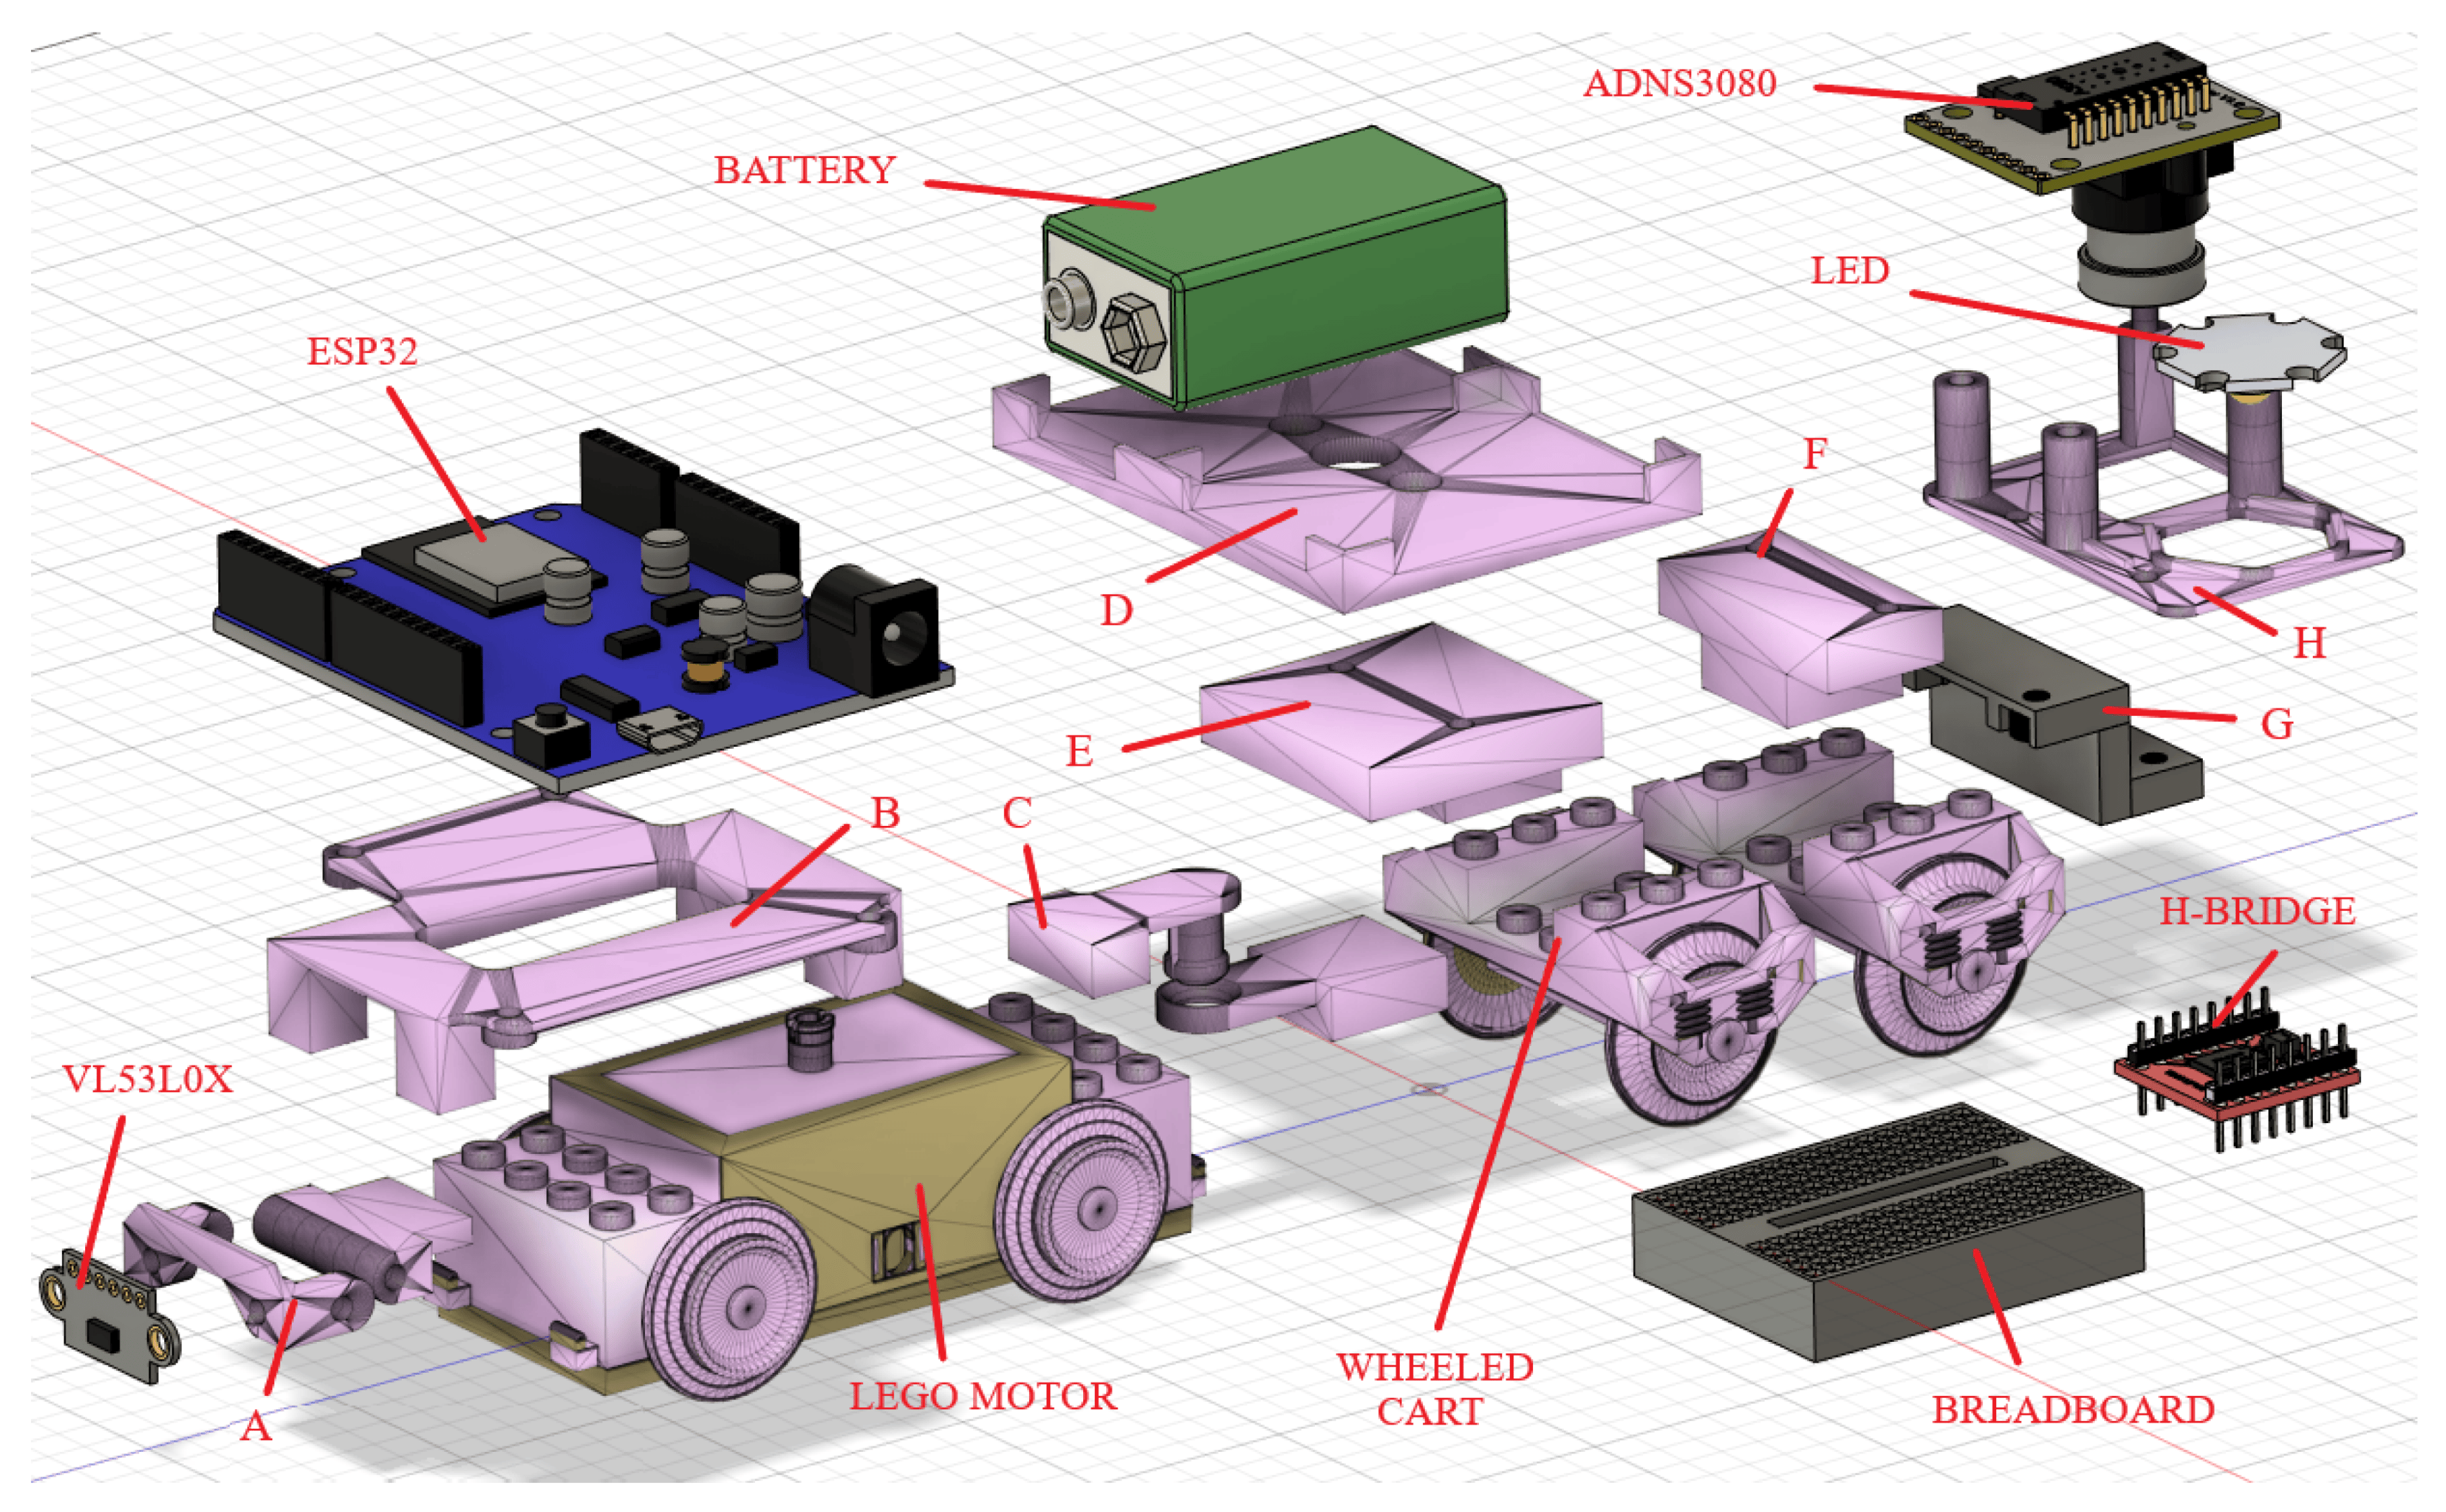
Low-cost, open-source hardware for testing platooning results and for teaching control: the PL-TOON train platoon and the RUPU line-following robots.
Research grants (as PI)
- ANID/FONDECYT Regular 1251406 (2025-2029): “Characterizing the Effects of Lossy Links in Cooperative Control and Parameter Estimation of Vehicular Platoons”
- ANID/FONDECYT Iniciación 11221365 (2022-2025): “Decentralized Formation Control of Multi-Agent Systems with Applications to Platooning Under Unreliable Communication”
- ANID/FONDECYT Postdoctorado 3160738 (2015-2018): “Theoretical Aspects of Formation Control of Vehicular Platoons”
Prospective students
I supervise undergraduate and graduate projects in control theory, multi-agent systems, string stability, robotics and automation, experimental validation of control algorithms, and data-driven methods in control. I am also an embedded systems enthusiast, and some projects use them in teaching or industrial applications.
If you are interested in the UAI postgraduate programs, the MCI (Magíster en Ciencias de la Ingeniería) or the DDS (Doctorado en Data Science), write to andres (dot) peters (at) uai (dot) cl.
News
| Oct 23, 2026 | Recent publications, 2025-2026 |
|---|---|
| Oct 23, 2026 | “String Stability for Predecessor-Leader Following Platoons with Additive Noise Channels” (F. Sanhueza, M. Gordon, M. Wang, J. Chen, A. Peters, F. Vargas) appeared in the proceedings of the 64th IEEE Conference on Decision and Control (CDC 2025). It is joint work with our collaborators at City University of Hong Kong. DOI |
| Oct 23, 2026 | Our paper “Mobile PL-TOON: A Laptop-Free, Phone-Based Control Laboratory” (with C. Fuentes) has been accepted at TICxEd 2026, part of the Jornadas Chilenas de Computación (JCC 2026) at Universidad de Talca. |
| Oct 23, 2026 | Our paper “Expectation-based string stability of predecessor-following platoons over lossy channels” (with A. I. Maass, F. J. Vargas, and J. I. Yuz) has been accepted for publication in Automatica. A preprint of an earlier version is on arXiv. |
| Feb 07, 2025 | Fondecyt Regular at UAI news! |